Can robotic electrostatic spraying really save paint? Which parameters are the deciding factors?
Why does electrostatic spraying save paint?
Traditional air based spraying relies on “propulsion” – compressed air blows the paint mist toward the workpiece. While some of it lands on the surface, the rest disperses into the air. In manual air spraying, paint utilization is typically only 30%–50%, resulting in significant waste.
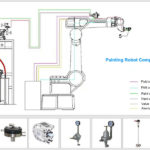
Electrostatic spraying, by contrast, relies on “attraction.” A high-voltage electrostatic charge is applied to the spray gun or rotary bell, causing the paint mist particles to become electrically charged. Since the workpiece is grounded, an electric field is created, which actively draws the charged paint mist toward the workpiece. Furthermore, because robots offer stable motion paths and high repeatability, issues like overspray or missed spots are drastically reduced.
When parameters are properly optimized, robotic electrostatic spraying can achieve a paint utilization rate of over 80% – and with an optimized rotary bell system, this figure can reach as high as 90%. In short, paint savings are not just a marketing gimmick; they are the result of the combined effects of electrostatic attraction, stable motion paths, and precise atomization control.
Key parameters that determine paint-saving performance
1) Electrostatic Voltage
Voltage determines the strength of the electric field. If the voltage is too low, the paint mist particles will not be sufficiently charged, leading to weak attraction and a lower transfer efficiency. Conversely, if the voltage is too high, it can cause electrical arcing (sparking) at corners or edges, as well as paint sagging or the formation of air bubbles. For liquid electrostatic spraying, the voltage is generally set between 60–90 kV, while rotary bell systems typically operate in the 50–80 kV range. The exact settings should be based on the equipment manufacturer’s recommendations and observations of any arcing on-site.
2) Spraying Distance
The spraying distance directly affects the electric field strength and the rate at which the paint mist reaches the workpiece. If the distance is too great, the electric field weakens, and the paint mist is likely to disperse into the air. If the distance is too short, while attraction may increase, the risk of arcing rises, and the resulting film thickness may become uneven. In robotic electrostatic spraying, the distance is usually maintained between 150–300 mm. When dealing with complex, curved surfaces, the robot must maintain a constant distance from the workpiece to ensure consistent application.
3) Rotary Bell Speed or Atomization Air Pressure
A higher rotary bell speed results in finer paint droplets and more uniform atomization. However, an excessively high speed can make the droplets too fine, leading to increased bounce-back and overspray. For solvent-borne coatings, the rotational speed for clear coats is typically around 35,000–40,000 rpm, while it is slightly lower for intermediate coats (surfacer/primer-surfacer) and base coats. For air-atomized electrostatic spray guns, the atomization air pressure must be carefully controlled; excessive pressure can disperse the charged paint mist, thereby reducing deposition efficiency.
4) Shaping Air
Shaping air controls the shape of the spray pattern and the trajectory of the paint mist. If the shaping air pressure is too high, the spray pattern becomes compressed, increasing the film thickness in the center while also causing more bounce-back. Conversely, if it is too low, the spray pattern becomes too wide, resulting in insufficient film thickness at the edges and an increased risk of paint contamination near the rotary bell. High-transfer-efficiency systems typically optimize the rotary bell design and shaping air to minimize bounce-back, thereby improving coating deposition efficiency.
5) Paint Flow Rate
The paint flow rate must be balanced with the conveyor line speed, target film thickness, and the solids content of the coating. An excessively high flow rate leads to coarser atomized droplets, reduced electrostatic attraction, and a higher risk of sagging (runs). An excessively low flow rate results in insufficient film thickness, which may necessitate additional spraying – ultimately increasing total consumption. The flow rate should not be adjusted in isolation; it must be considered in conjunction with the rotary bell speed, shaping air, and the movement speed of the robotic applicator.
6) Coating Resistivity and Viscosity
Electrostatic spraying is highly sensitive to the electrical properties of the coating. If the resistivity is too high, the coating is difficult to charge; if it is too low, current leakage may occur, compromising the stability of the high-voltage system. For liquid electrostatic coatings, the resistivity must be matched to the specific type of spray gun, typically falling within the range of 5–50 MΩ·cm. Viscosity affects both atomization and the “wrap-around” effect; excessively high viscosity leads to poor atomization, while excessively low viscosity increases the risk of sagging. Generally, the viscosity used for electrostatic spraying is slightly lower than that used for conventional air spraying.
7) Workpiece Grounding
This is the point most frequently overlooked. If a workpiece is poorly grounded, electric charges cannot dissipate, which significantly reduces the adhesion of the paint mist and can even cause the paint particles to bounce off the surface. This is particularly critical for plastic parts, resin bumpers, and composite components, which must be reliably grounded using conductive clamps, conductive strips, or specialized fixtures.
8) Airflow Velocity in the Spray Booth
Unlike conventional air spraying, electrostatic spraying does not require high airflow velocities to force the paint mist onto the surface. Excessive airflow can blow the charged paint mist out of the electric field, reducing deposition efficiency; conversely, insufficient airflow hinders the collection of excess paint mist and the effective control of VOC emissions. A velocity of approximately 0.5–0.7 m/s is generally recommended.
9) Robot Trajectory and Spray Pattern Overlap
The paint-saving capability of a robot also stems from the precision of its movement. Poor trajectory planning – resulting in excessive overlap – leads to paint buildup, while insufficient overlap results in missed spots. For edges, corners, and recessed areas, the robot’s speed and flow rate must be specifically optimized to prevent localized excessive coating thickness. An ideal trajectory is not about applying as much paint as possible, but rather ensuring precise coverage that meets the required specifications.
Conclusion
While electrostatic spraying robots can indeed save paint, this efficiency is the result of a coordinated set of controls: stable voltage, precise distance, fine atomization, matched flow rates, reliable grounding, and well-planned trajectories. These parameters are interdependent; if any one of them deviates, the advantages of electrostatic spraying will be negated. A truly sophisticated electrostatic spraying line is not one where parameters are pushed to their “maximum” settings, but rather one where they are tuned for the “optimal balance.”